


Файл:PID Compensation Animated.gif
PID_Compensation_Animated.gif (400 × 300 пкс, размер файла: 401 КБ, MIME-тип: image/gif, закольцованный, 250 фреймов, 20 с)
Примечание: По техническим причинам миниатюры подобных GIF-изображений высокого разрешения не анимируются.
Описание
| Описание | In a unity feedback configuration, an ideal PID compensator is used to enhance the step response of a system with the transfer function
<img alt="{\displaystyle G_{p}={\frac {1}{s^{2}+1.33s+1 |
|---|---|
| Источник | |
| Время создания | |
| Автор или правообладатель | |
| Другие версии файла | — |


}" aria-hidden="true" class="mwe-math-fallback-image-inline mw-invert" src="https://wikimedia.org/api/rest_v1/media/math/render/svg/7cc3dc3563798adcee8df326a7a7d678dfed081a" style="vertical-align: -2.338ex; width:21.033ex; height:5.676ex;"/>
The PID controller has the standard form Kp+Ki/s+Kds. Therefore, the closed loop transfer function of the whole system becomes
<img alt="{\displaystyle G={\frac {G_{c}G_{p}}{1+G_{c}G_{p}}}={\frac {K_{d}s^{2}+K_{p}s+K_{i}}{s^{3}+(1.33+K_{d})s^{2}+(1+K_{p})s+K_{i}}}}" aria-hidden="true" class="mwe-math-fallback-image-inline mw-invert" src="https://wikimedia.org/api/rest_v1/media/math/render/svg/672f02e08b2d8f513be9db18606700ead10e82ea" style="vertical-align: -2.671ex; width:56.723ex; height:6.676ex;"/>
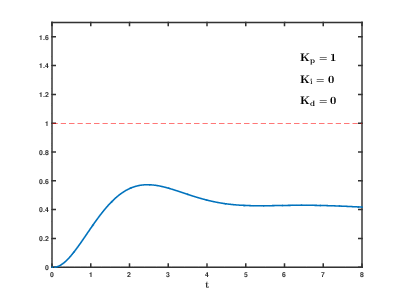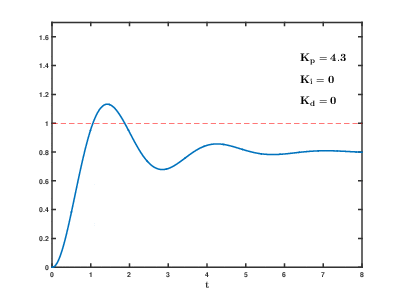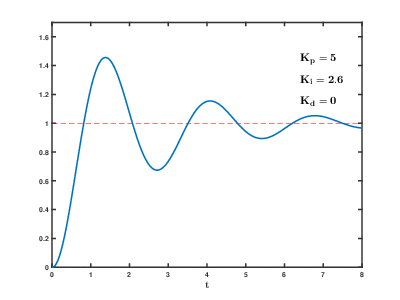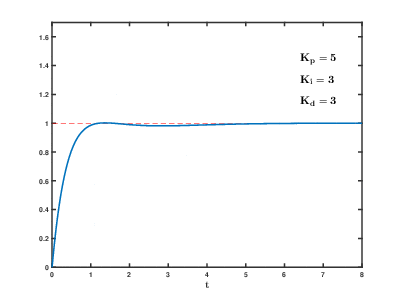
As the proportional, integral and derivative terms of the PID compensator are increased, the evolution of the step response, from the initial uncompensated response (corresponding to PID coefficents Kp=1, Ki=0, Kd=0) to the final desired response is depicted. The following effects of PID compensation can be readily observed:
- The proportional term increases the speed of the system. It also decreases the residual steady state error of the step response, but can not eliminate it completely.
- The integral term eliminates the residual steady state error of the step response, but adds undesired "oscillations" to the transient response (overshoot).
- The derivative term "damps out" the undesired oscillations in the transient response.
| источник = Own work | время создания = 2015-05-28 | автор = Physicsch — Лицензия: CC0 (Creative Commons Zero, Public Domain Dedication) http://creativecommons.org/publicdomain/zero/1.0/deed.en }} Источник файла — сайт Wikimedia Commons, куда он был загружен под одной из свободных лицензий ( https://commons.wikimedia.org/wiki/File:PID_Compensation_Animated.gif ). Авторов, работавших над этим файлом см. в истории файла: https://commons.wikimedia.org/w/index.php?title=File:PID_Compensation_Animated.gif&action=history


В общем случае в статьях энциклопедии Руниверсалис файлы используются в соответствии со статьёй 1274 Гражданского кодекса Российской Федерации.
История файла
Нажмите на дату/время, чтобы увидеть версию файла от того времени.
| Дата/время | Миниатюра | Размеры | Участник | Примечание | |
|---|---|---|---|---|---|
| текущий | 08:37, 16 декабря 2023 | | 400 × 300 (401 КБ) | I, Robot (обсуждение | вклад) | == Описание == {{Изображение | описание = In a unity feedback configuration, an ideal PID compensator is used to enhance the step response of a system with the transfer function <p><span class="mwe-math-element"><span class="mwe-math-mathml-inline mwe-math-mathml-a11y" style="display: none;"><math alttext="{\displaystyle G_{p}={\frac {1}{s^{2}+1.33s+1}}}" xmlns="http://www.w3.org/1998/Math/MathML"><semantics><mrow class="MJX-TeXAtom-ORD"><mstyle displaystyle="true" scriptlevel="0"><msub><mi>... |
Вы не можете перезаписать этот файл.
Использование файла
Следующий файл является дубликатом этого файла (подробности):

- Файл:PID Compensation Animated.gif на общем хранилище
Следующая страница использует этот файл:
